Safe Physical AI in Urban Mobility
We’re happy to share our latest paper, “Ensuring Safe Physical AI in Urban Mobility via Hazard-Informed Synthesized Envelopes”, to be presented at CRET 2026.
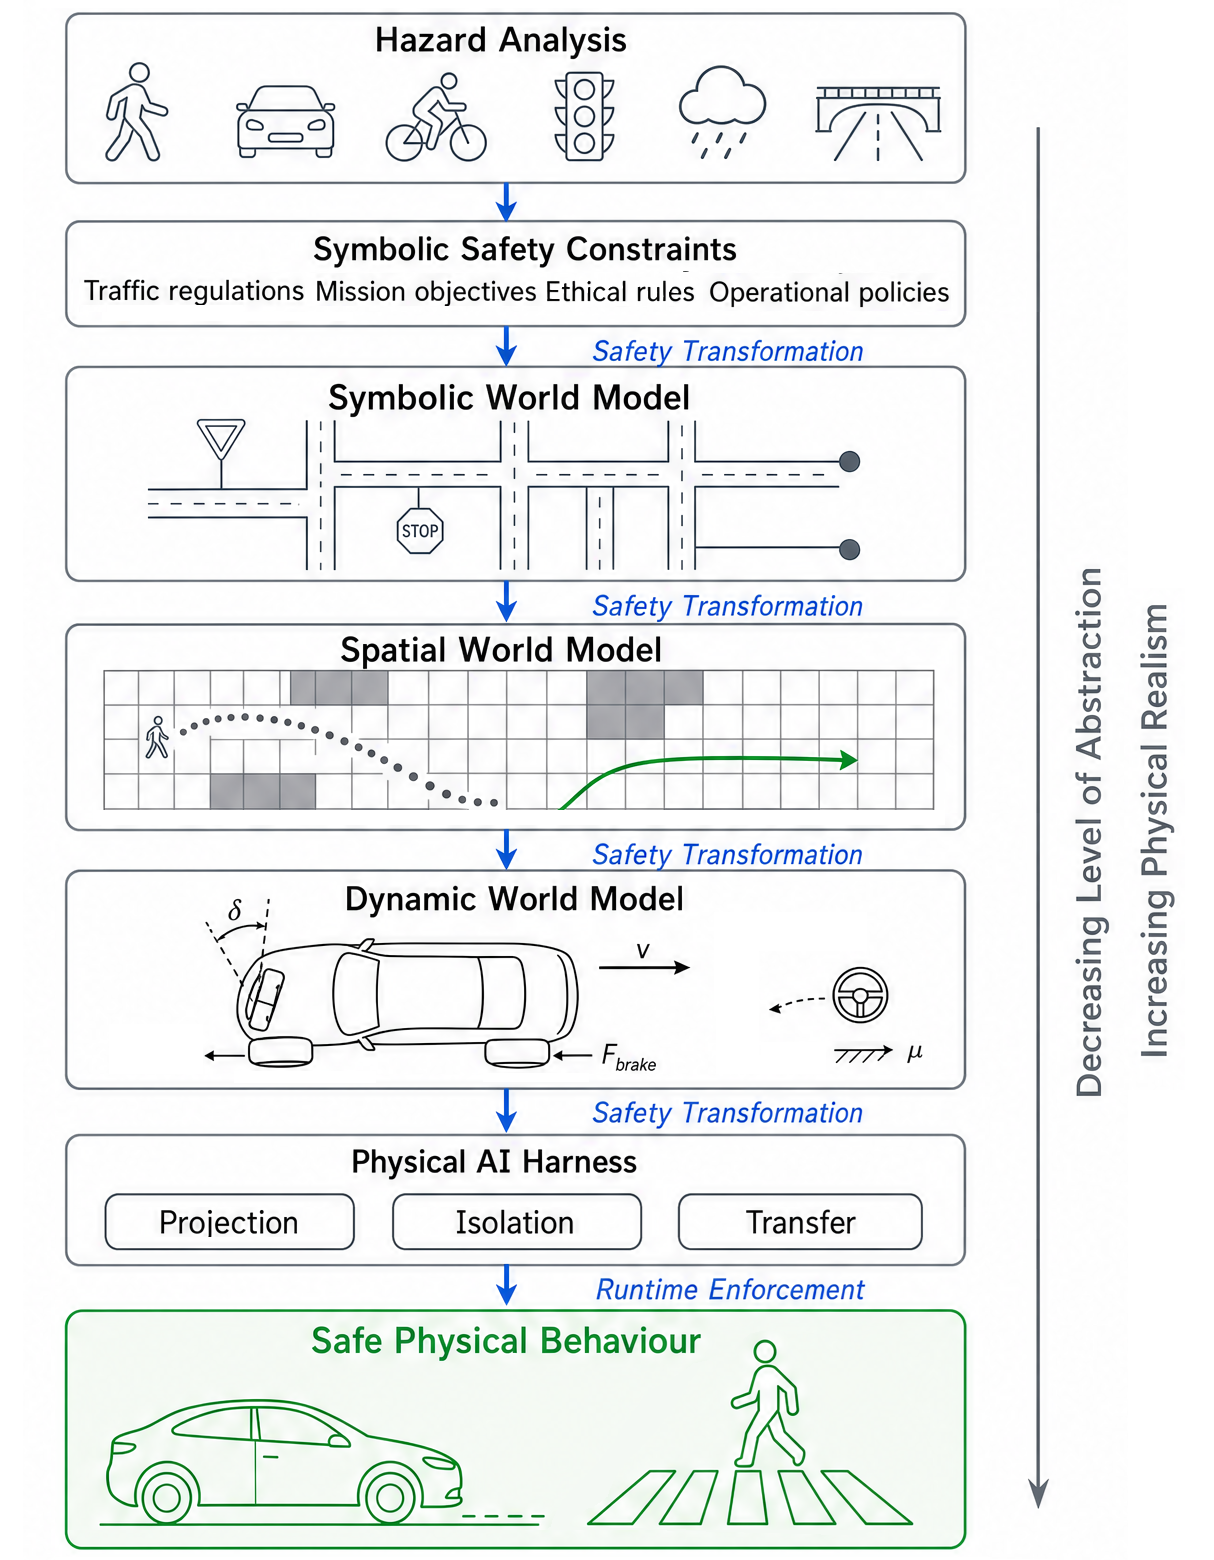
The paper introduces a unified framework for improving the safety of Physical AI systems in complex urban environments. By connecting systematic hazard analysis with runtime safety enforcement, the approach transforms safety requirements across symbolic, spatial, and dynamic world models into hazard-informed safety envelopes.
These envelopes help ensure safer interactions between humans and heterogeneous robotic systems operating in urban spaces.
🔗 Read the paper: https://arxiv.org/abs/2608.14481