Our project to be presented at the International Conference on Automation and Mechatronics Engineering
Our paper has been accepted for presentation at the International Conference on Automation and Mechatronics Engineering (ICAME’2026).
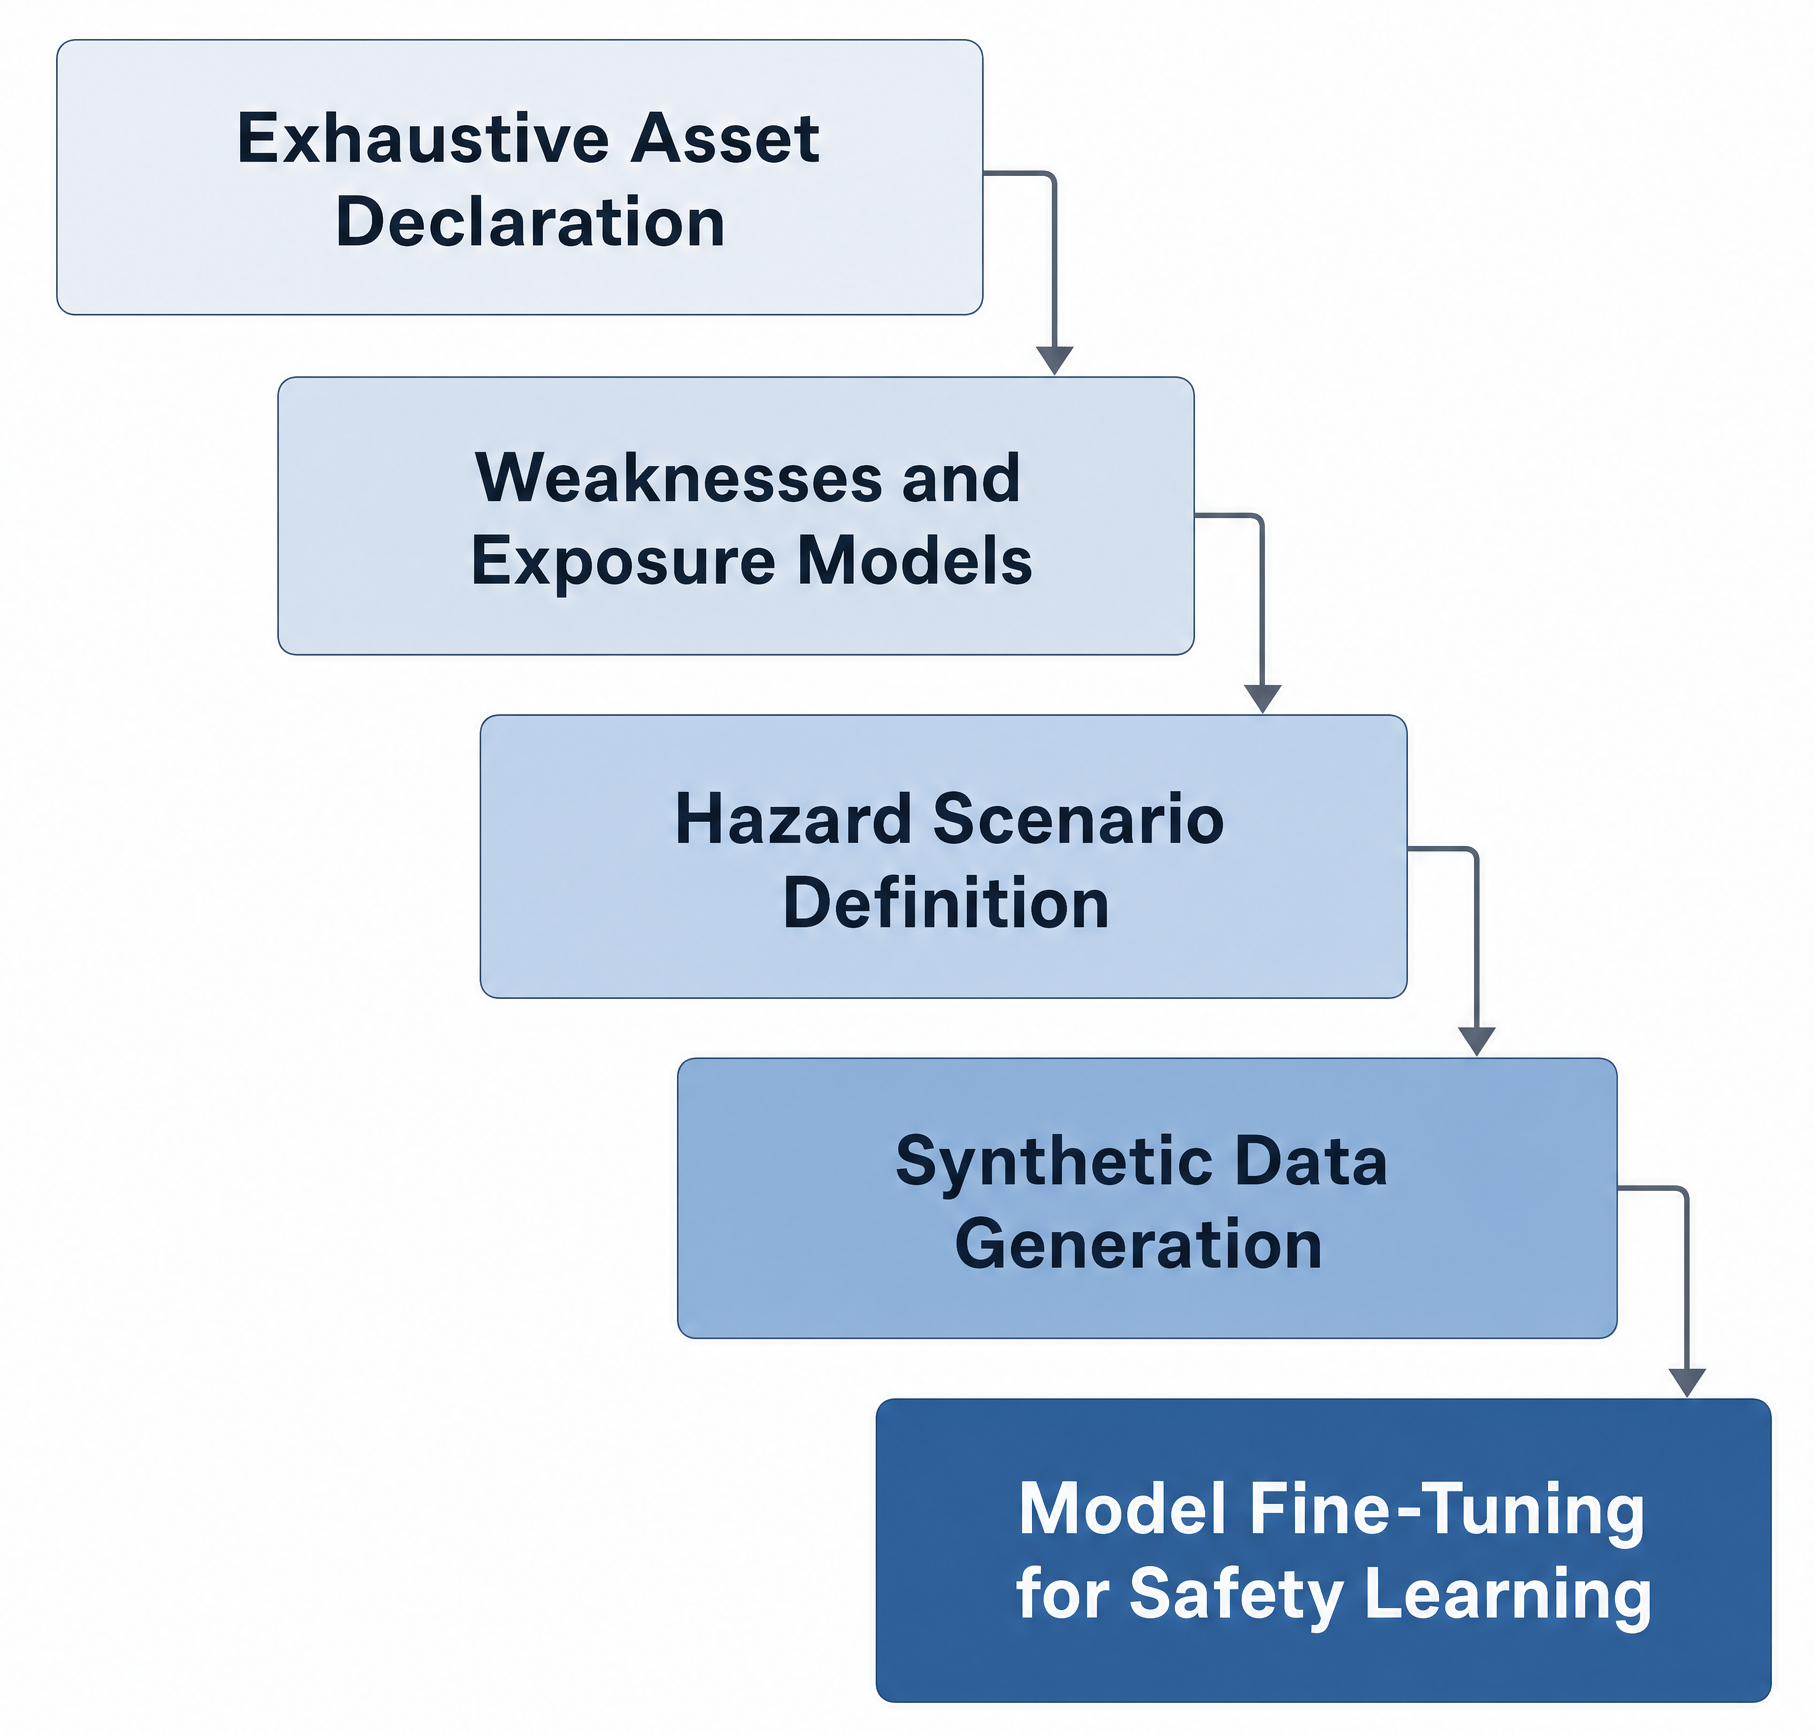
We present a structured Robotics Physical Safety Framework that explicitly links:
✅ Asset declaration
✅ Vulnerability enumeration
✅ Hazard-driven synthetic data generation
By aligning classical risk engineering (hazard ontologies) with digital twin simulation and ML training pipelines, our approach enables “safety envelope learning” that is grounded in formal hazard analysis.
See the paper draft on Arxiv.org: “A Hazard-Informed Data Pipelinefor Robotics Physical Safety”.